 a brand of UAV-DEV GmbH
Omnidirectional propulsion
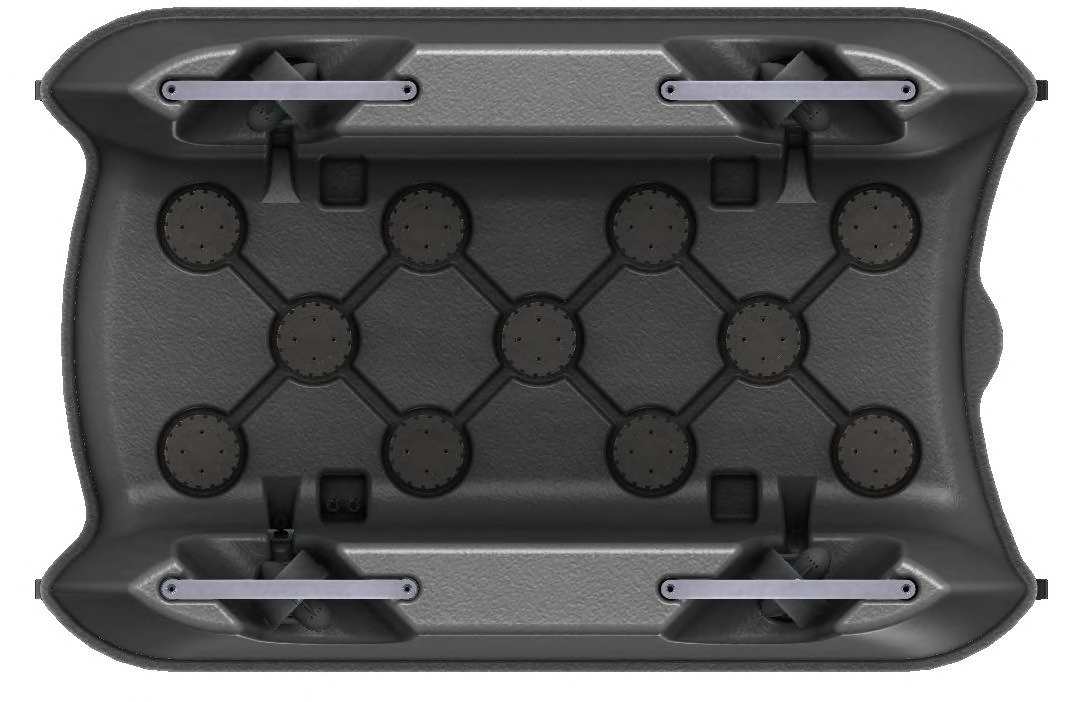
Four thrusters allow movement in any direction regardless of heading. Hold position, hold heading, approach a sheet pile wall sideways. If two thrusters fail, the boat still comes home.
Multi-Sensor USV
An unmanned autonomous boat that carries your sensors: 10 kg payload on 20 generic mounts, RTK GNSS with heading, redundant propulsion and about 12 hours of endurance. Developed, built and field-proven by UAV-DEV GmbH in Bremerhaven, made in Germany.
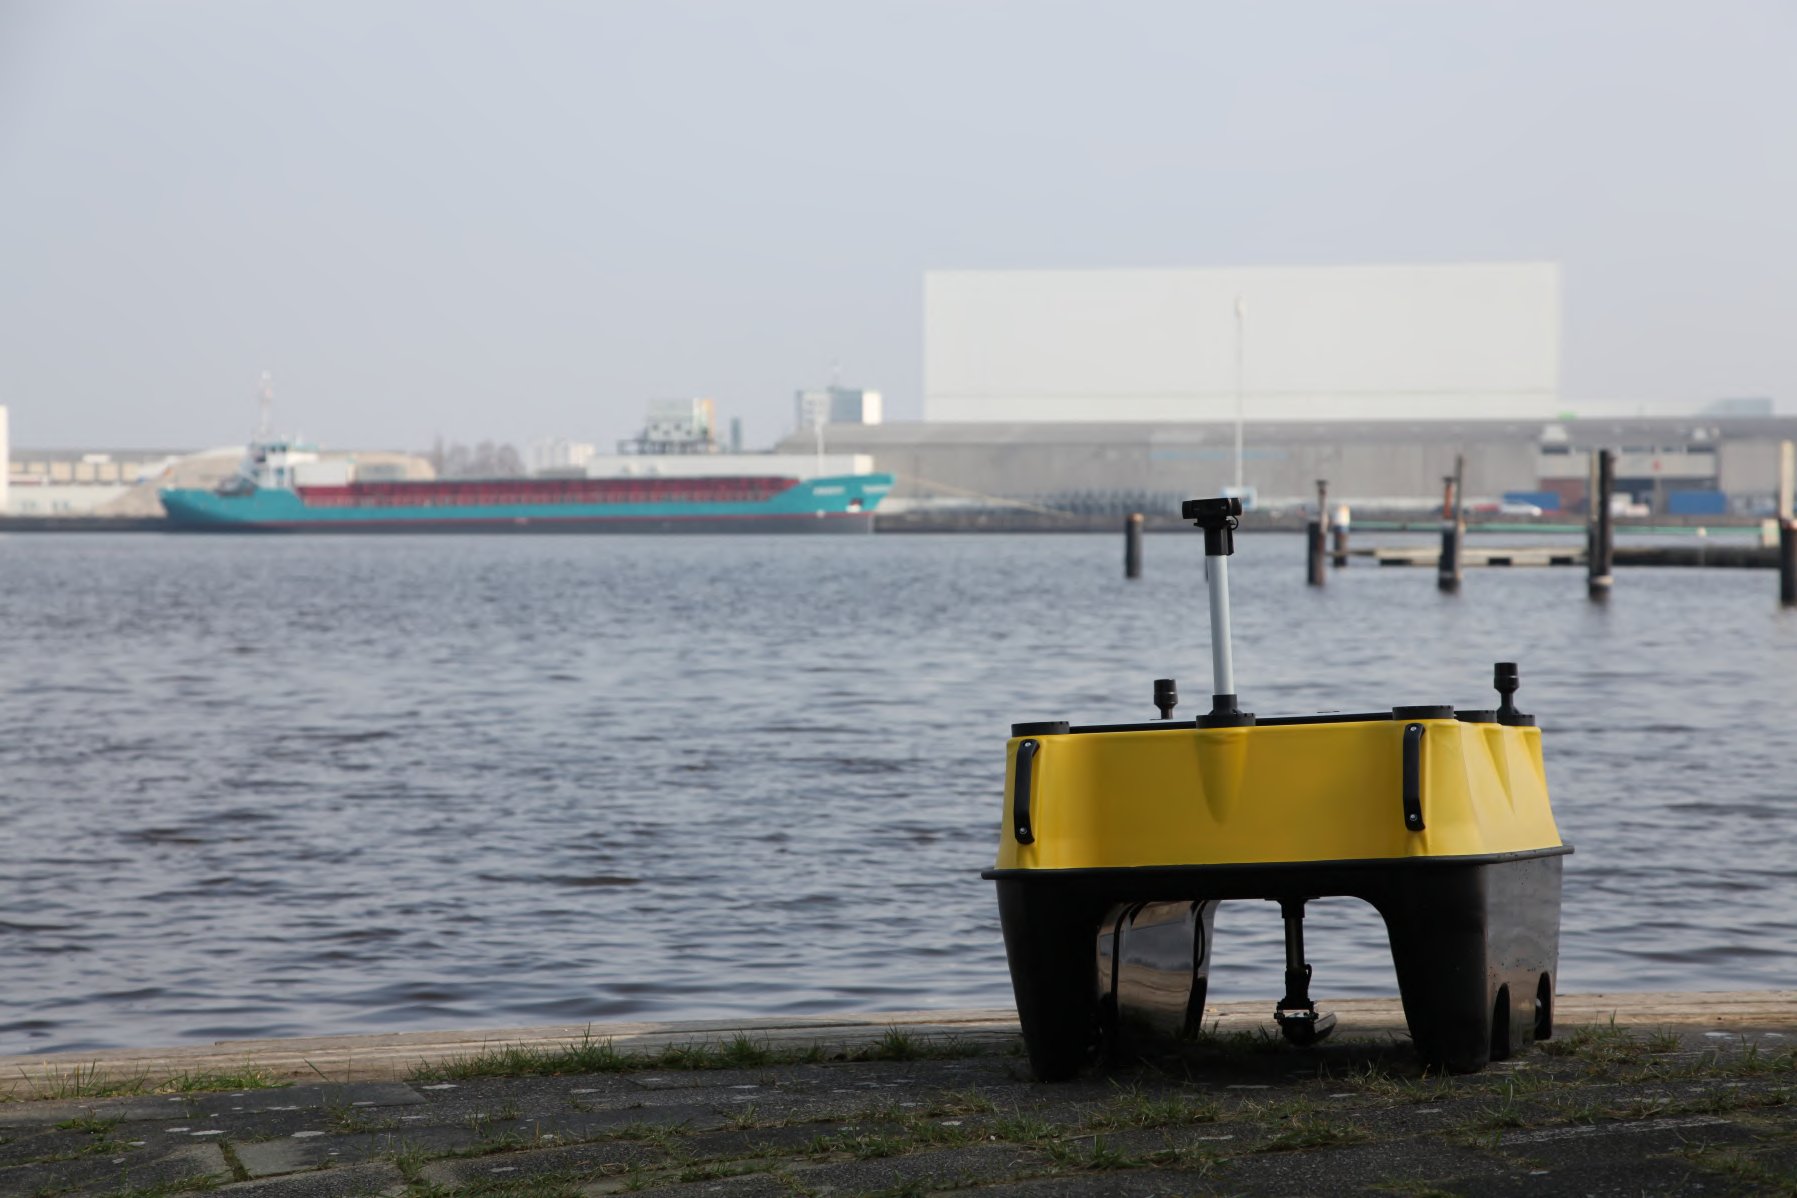 120 × 80 × 56 cm · 36 kg · Made in Germany
Technical data
Design
The payload interface is the core of the SensorBoat: mechanical fastening, cable routing and sealing in one part. Your adapter comes out of a 3D printer.
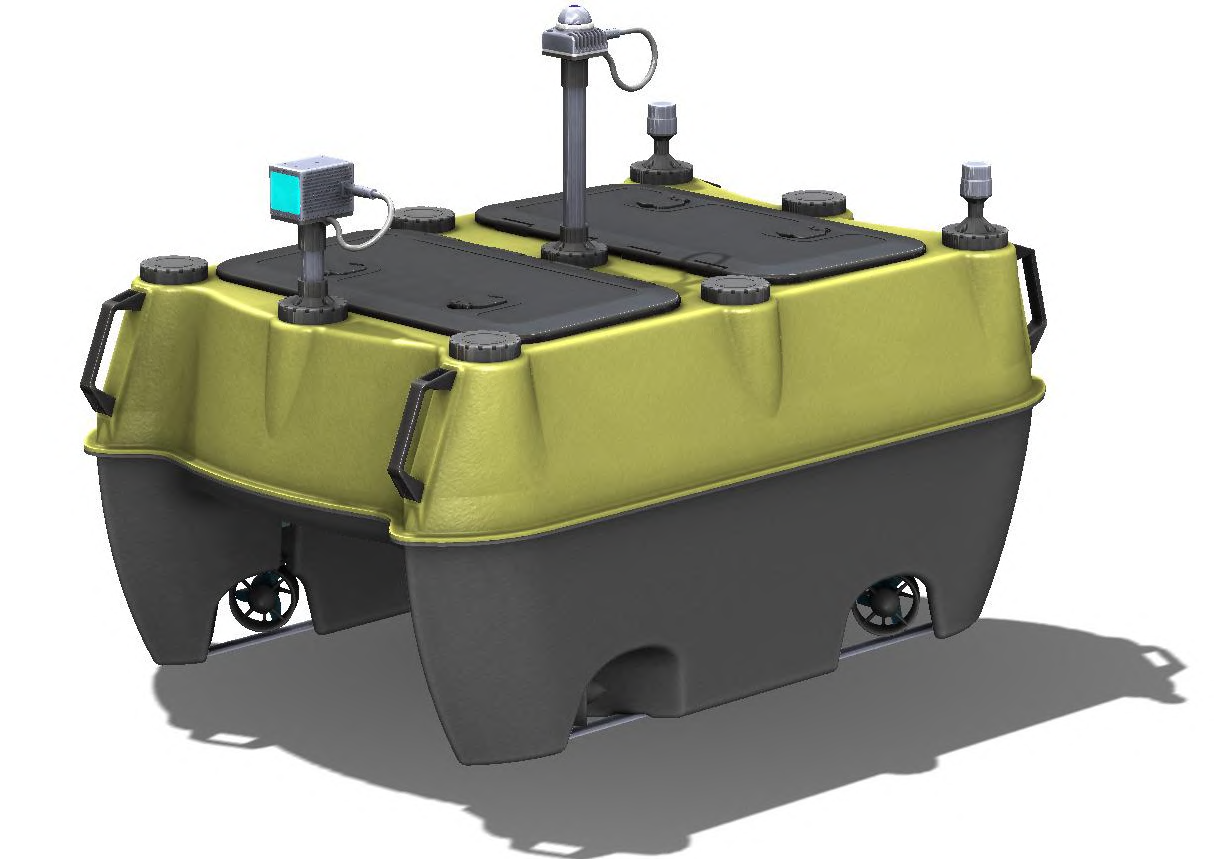
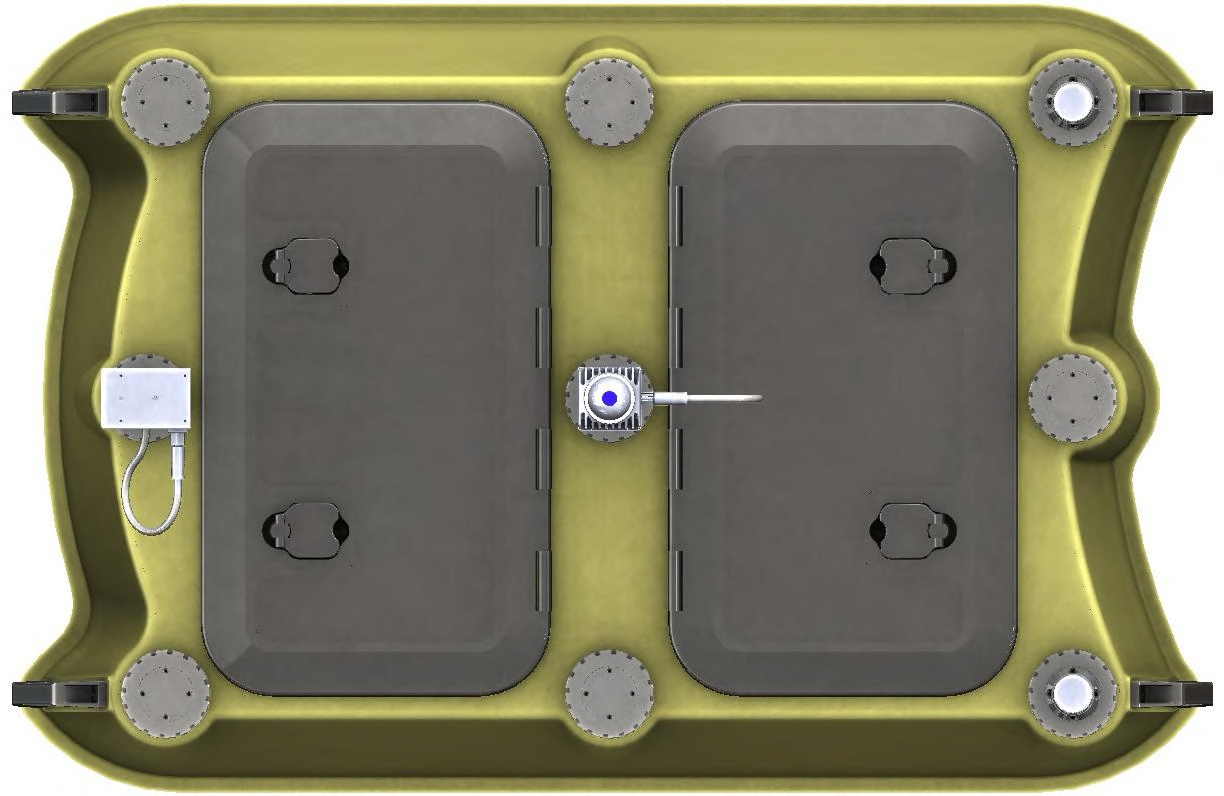
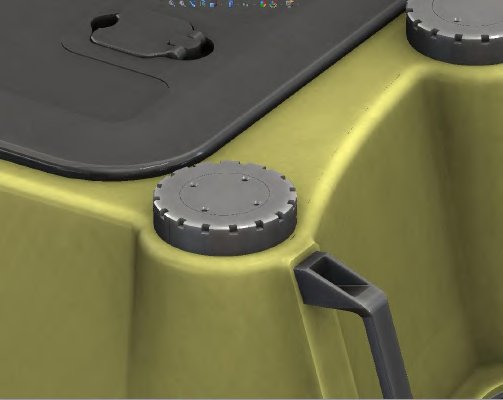
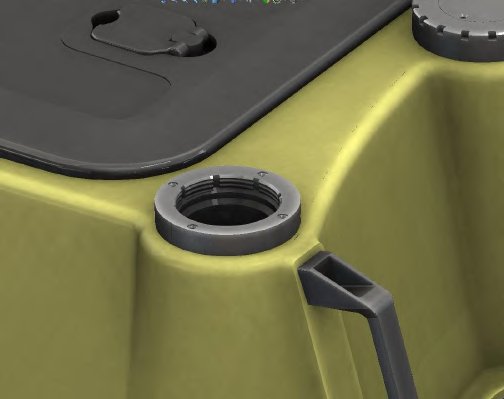
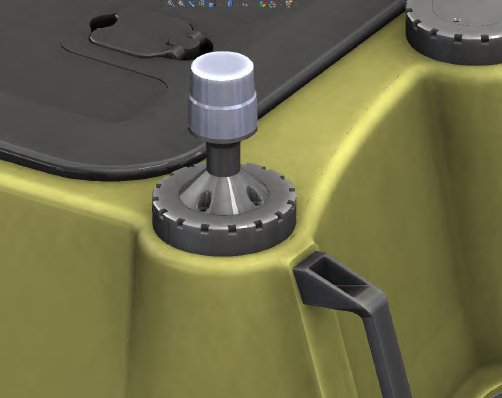
Generic mount: closed, open, with sensor adapter.
Four thrusters allow movement in any direction regardless of heading. Hold position, hold heading, approach a sheet pile wall sideways. If two thrusters fail, the boat still comes home.
Plan survey lines, upload, go. Live video and telemetry reach the shore via 4G/5G. Missions can be paused, resumed and replaced by new ones while under way.
Depth and side-scan imagery are transmitted while the boat is running. You control the sonar from SonarView or your own software while the boat follows the lines.
The L1/L2/L5 RTK receiver provides position and heading at centimetre level, the basis for georeferenced depth data and repeatable survey lines.
1.5 kWh LiFePO4 is enough for about 12 hours or 34 km. A sand pit of around ten hectares is fully covered in one morning.
ArduPilot as vehicle control, documented interfaces, standard components. We integrate your sensor or use case. That is part of our offer.
In the field
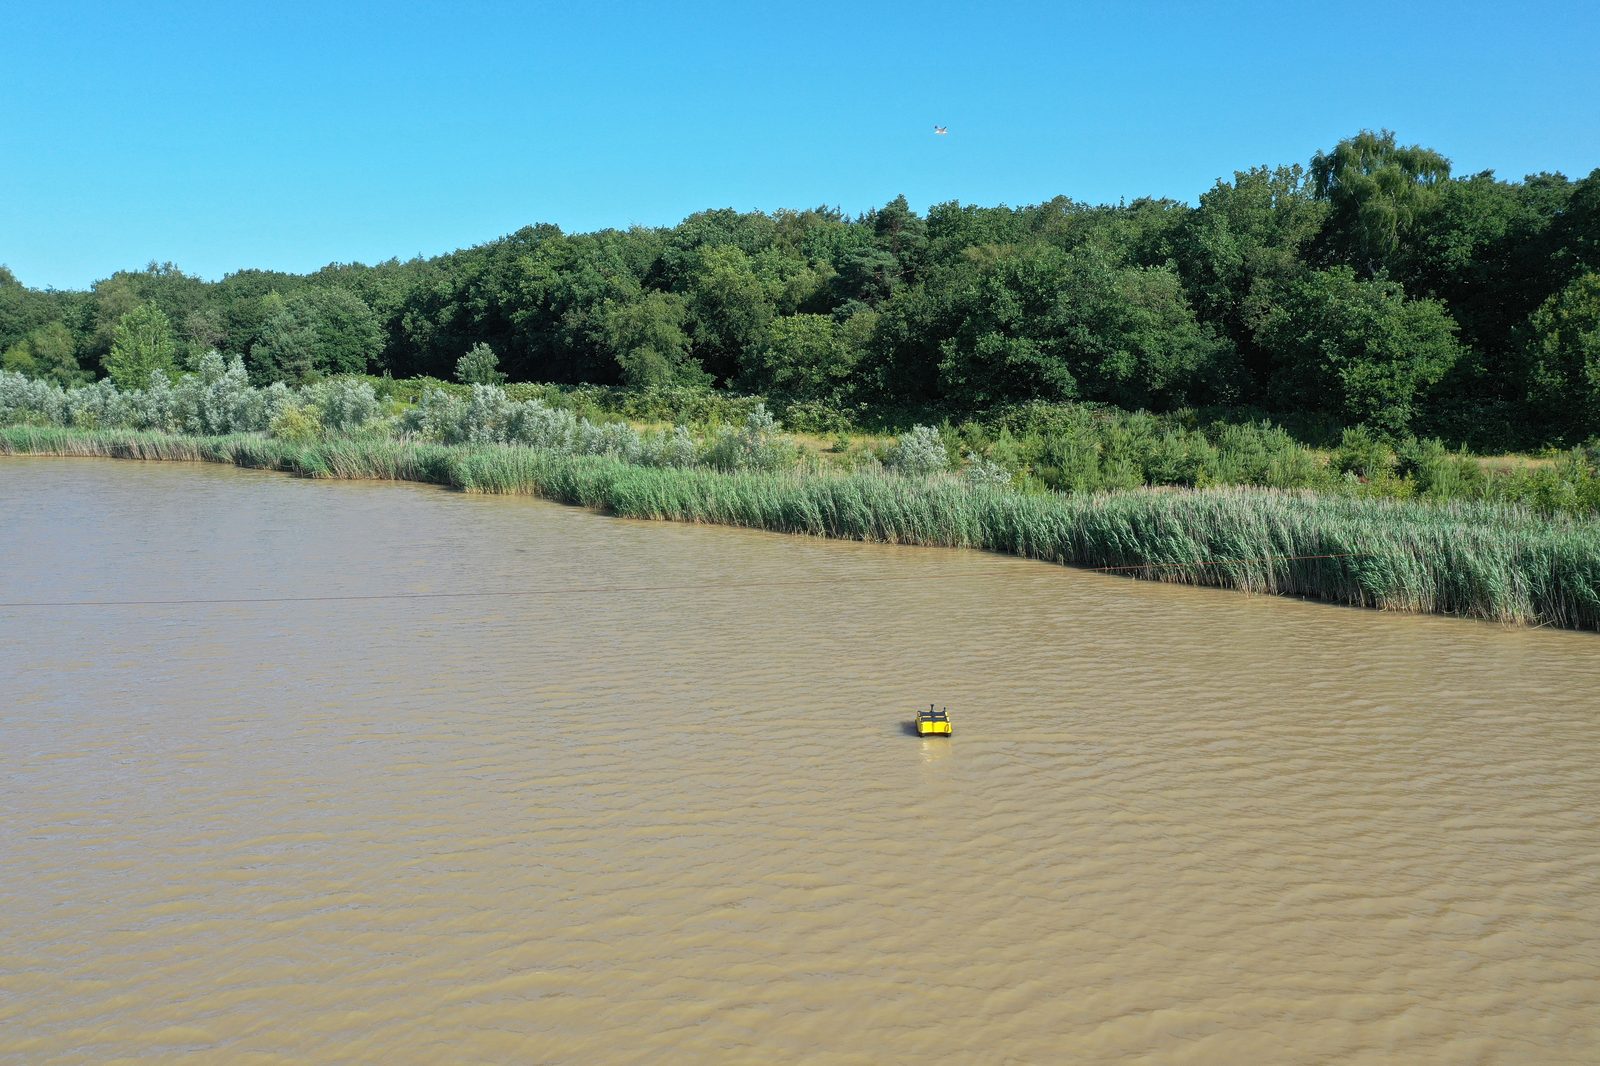
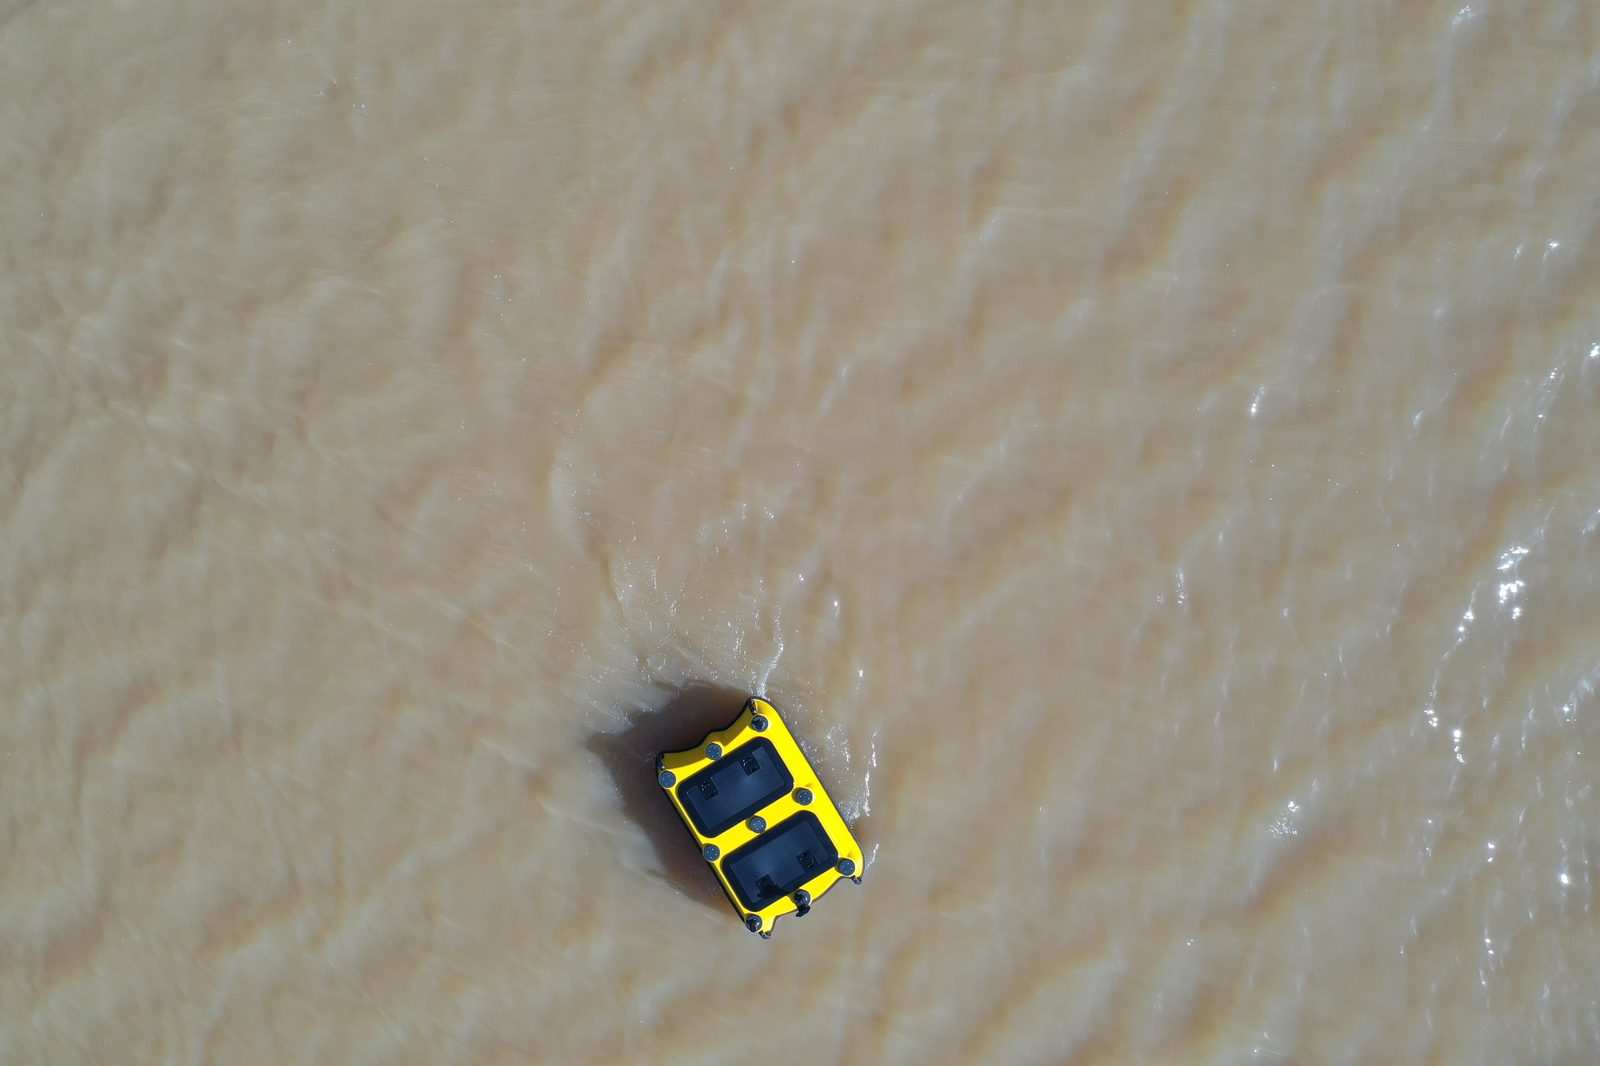
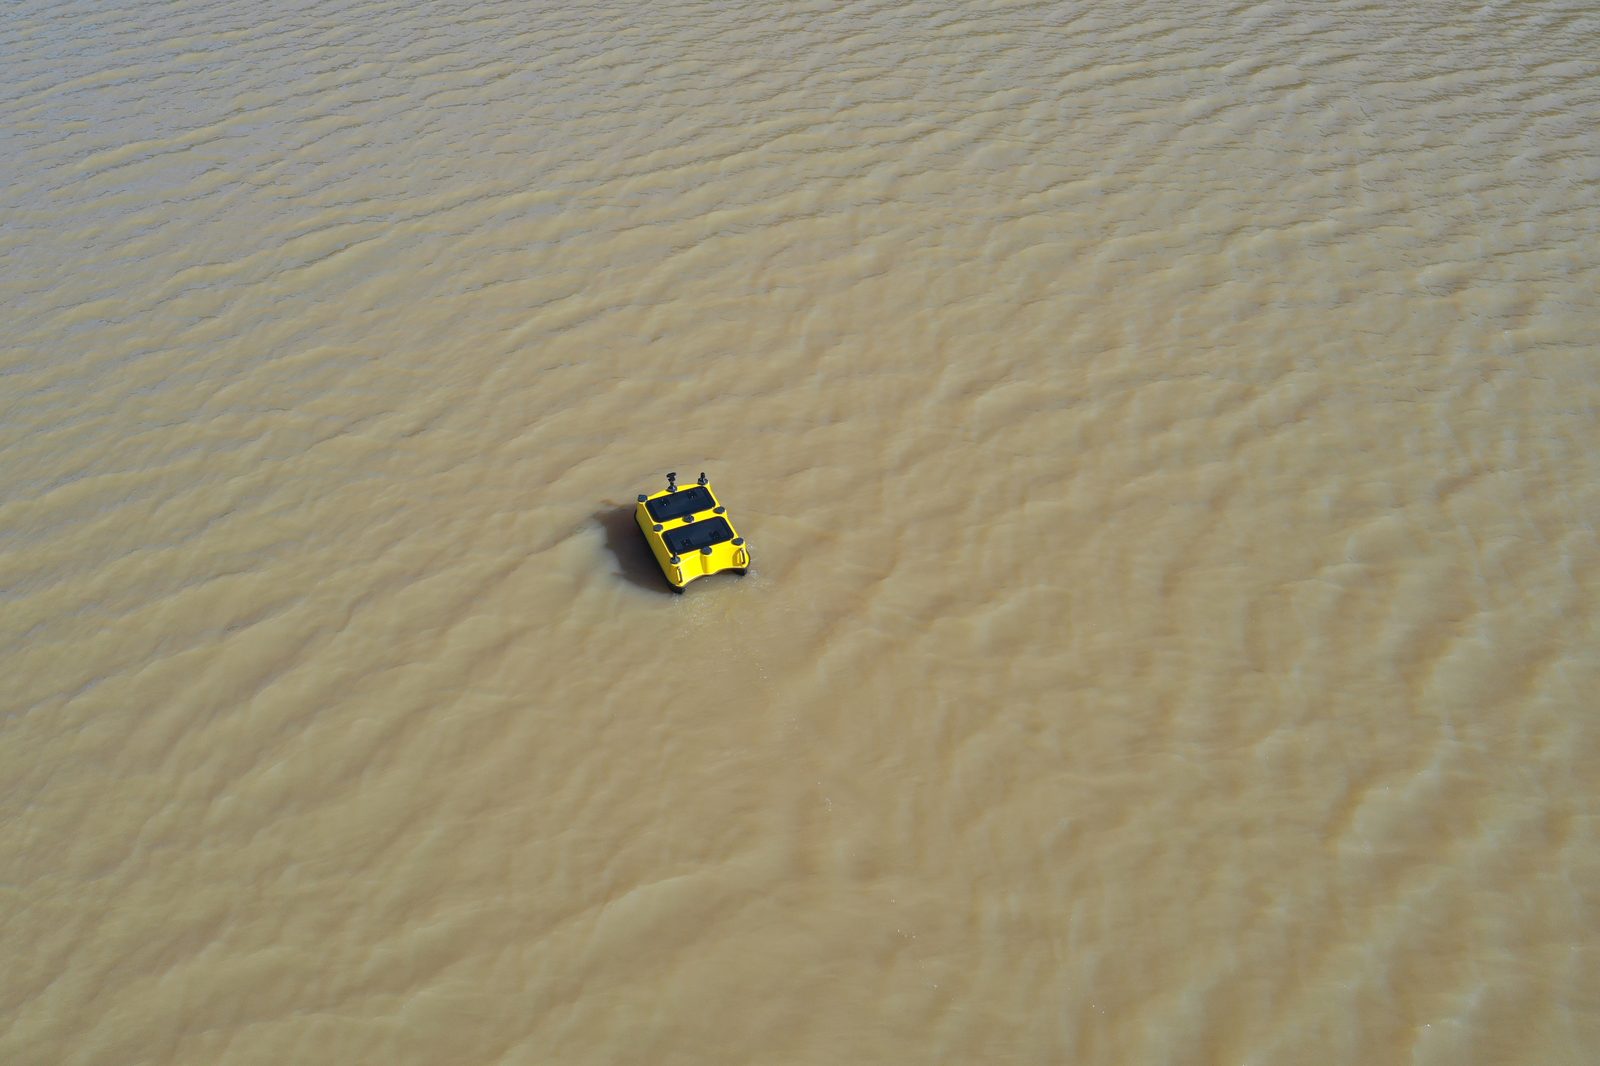
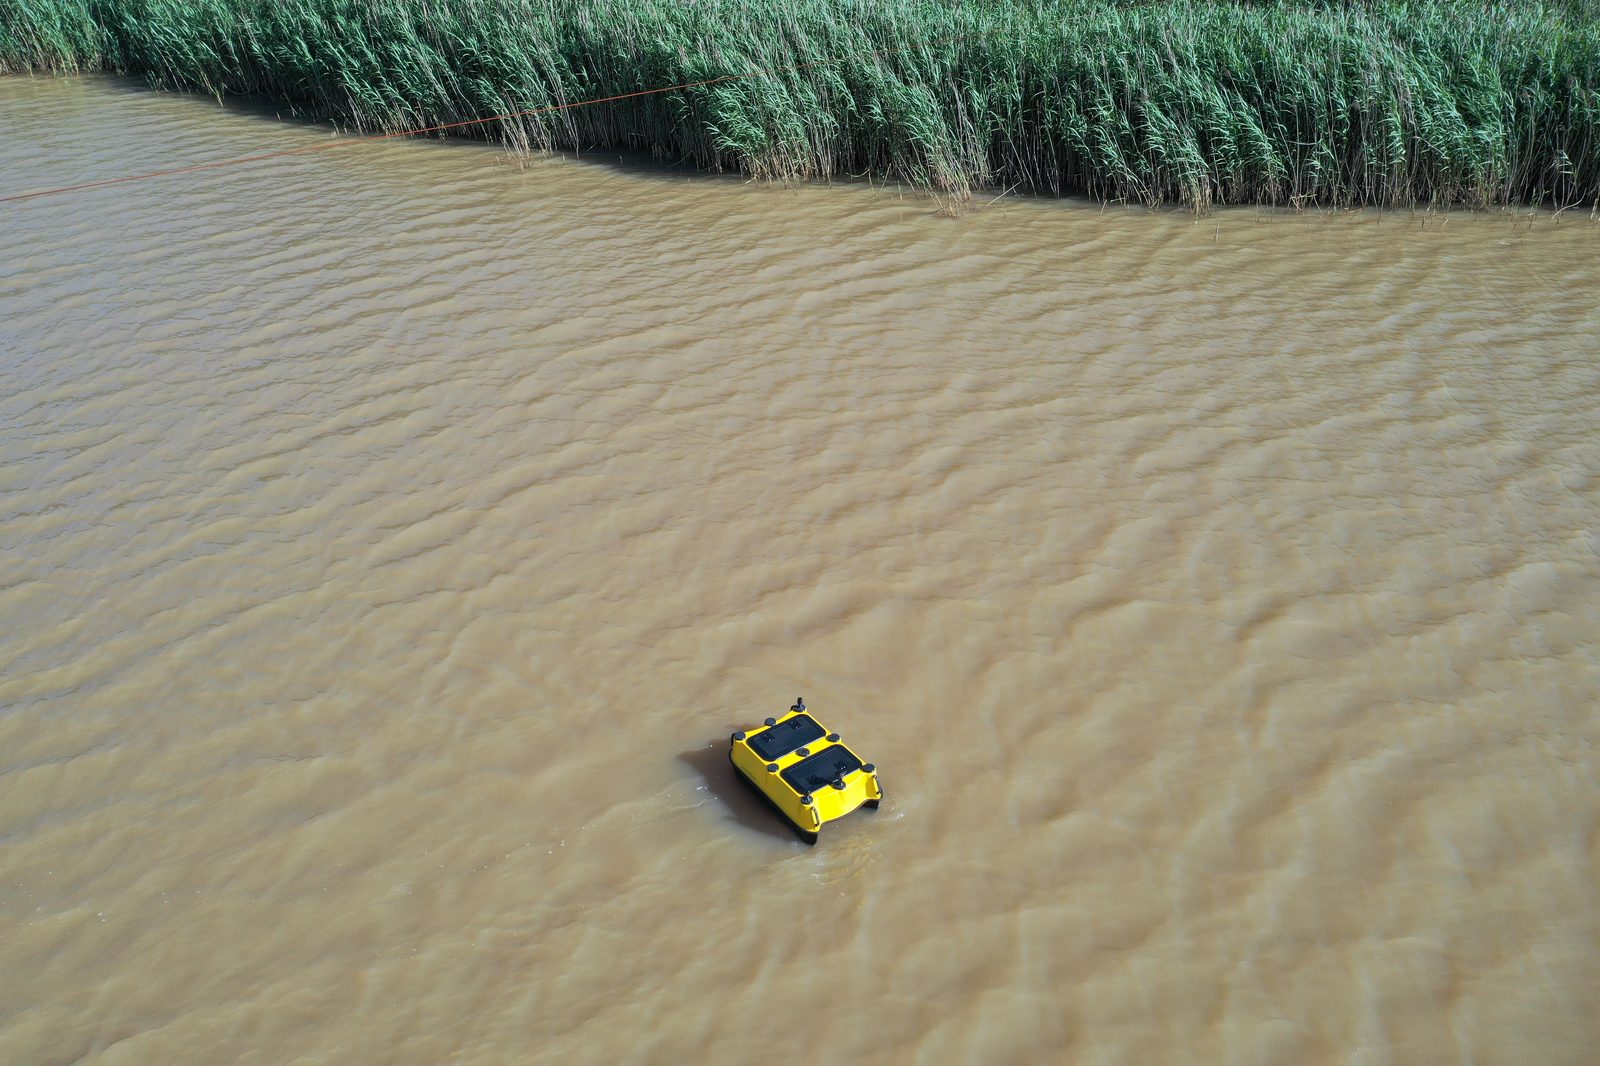
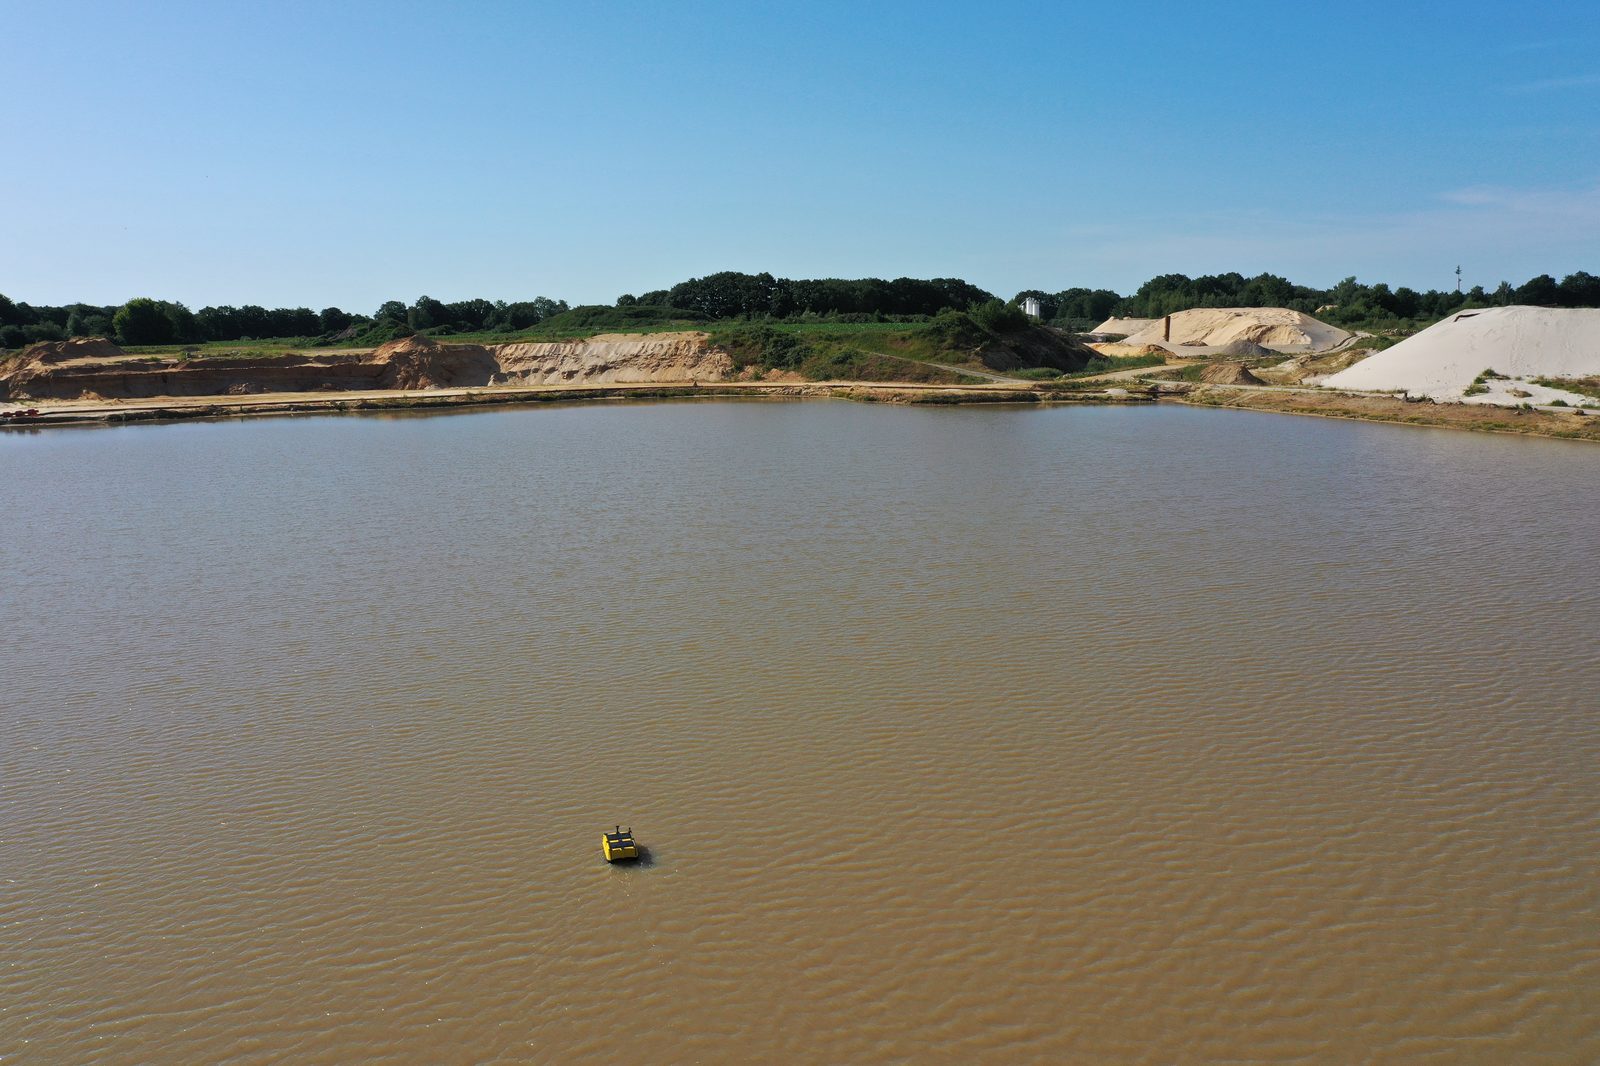
About four hours of autonomous survey lines in sunshine and light wind. All photos were taken by the drone that also delivered the orthophoto for the evaluation.
FAQ
An unmanned autonomous boat (USV, unmanned surface vehicle) for surveying and sensing on inland waters and in harbours. It carries up to 10 kg of payload, runs survey lines autonomously with ArduPilot and is built in Bremerhaven, Germany.
Multibeam and single-beam echo sounders, side-scan sonars, cameras, water quality probes, samplers and your own sensors. 20 generic mounts with fastening, cable routing and sealing take a 3D-printed adapter for your sensor.
The SensorBoat is available as a product, lead time on request. Alternatively we survey your waters as a service with our own boat and staff.
About 12 hours or roughly 34 km at 0.8 m/s on the 1.5 kWh LiFePO4 battery. Propulsion with four T200 thrusters is redundant: the boat returns even with two thrusters down.
Tell us what the boat should carry. We check weight, power supply and data connection and send you a quote including the payload adapter.